 BlinkThorLabs
A Week Teaching MentorPi to Follow a Line (And Actually Understanding Why It Works)
Monday to Friday, one road mat, one stubborn ceiling light, and the moment lane_detect.py finally made sense.
Prototype builds, weekend hacks, and the first time a demo actually drives itself.
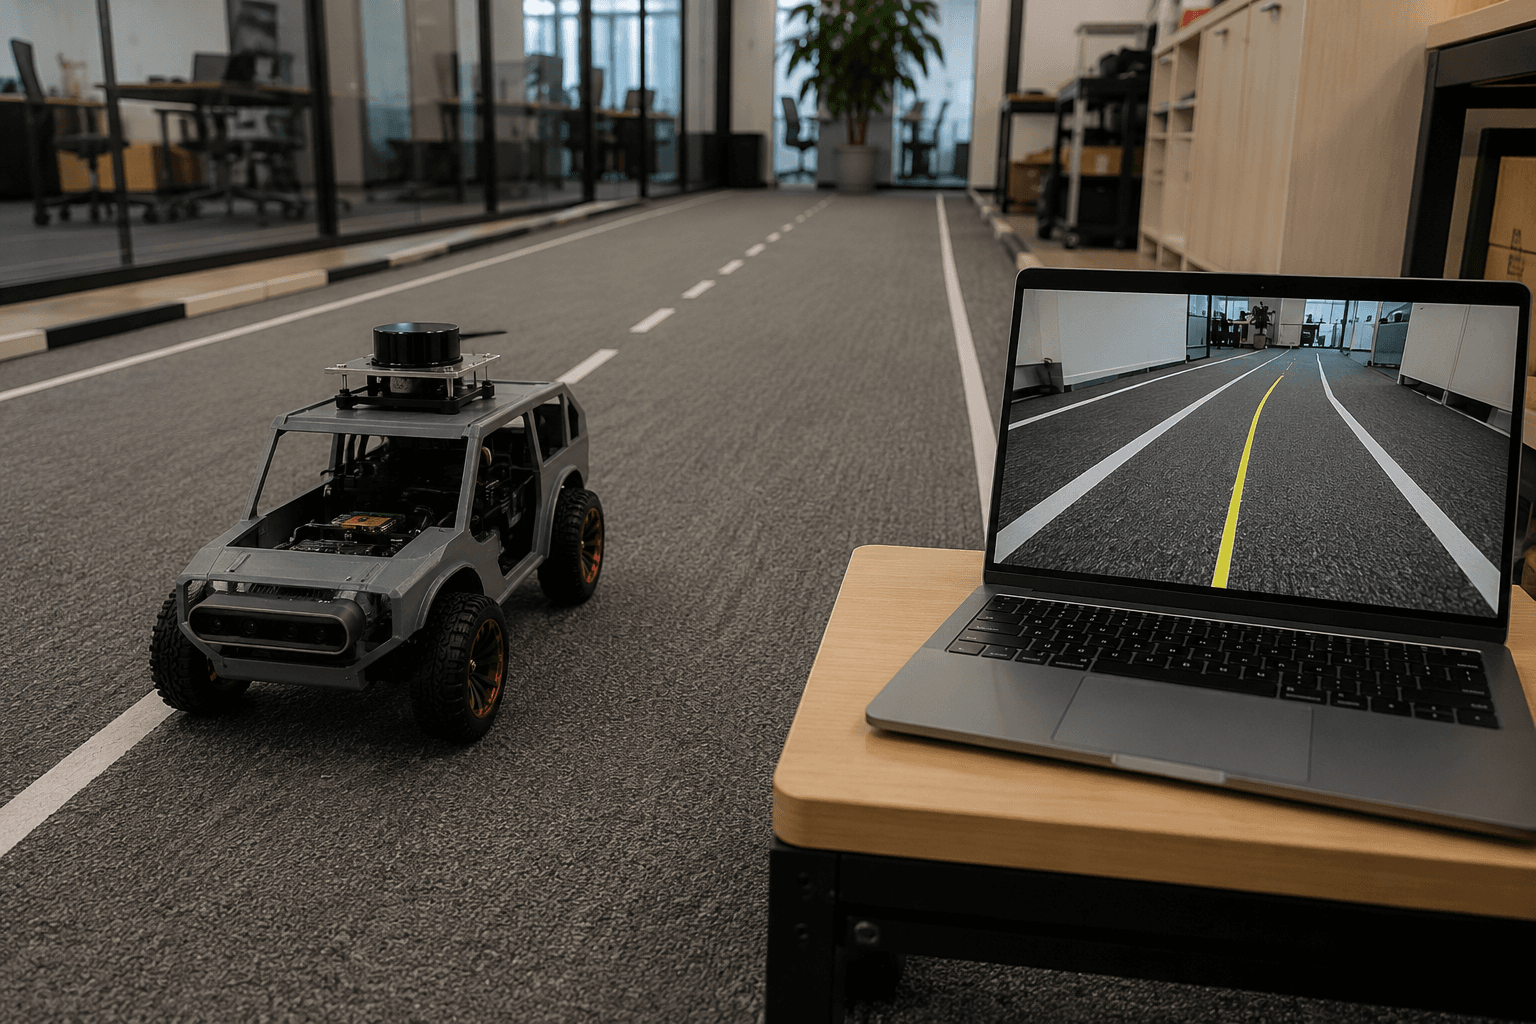
Monday to Friday, one road mat, one stubborn ceiling light, and the moment lane_detect.py finally made sense.
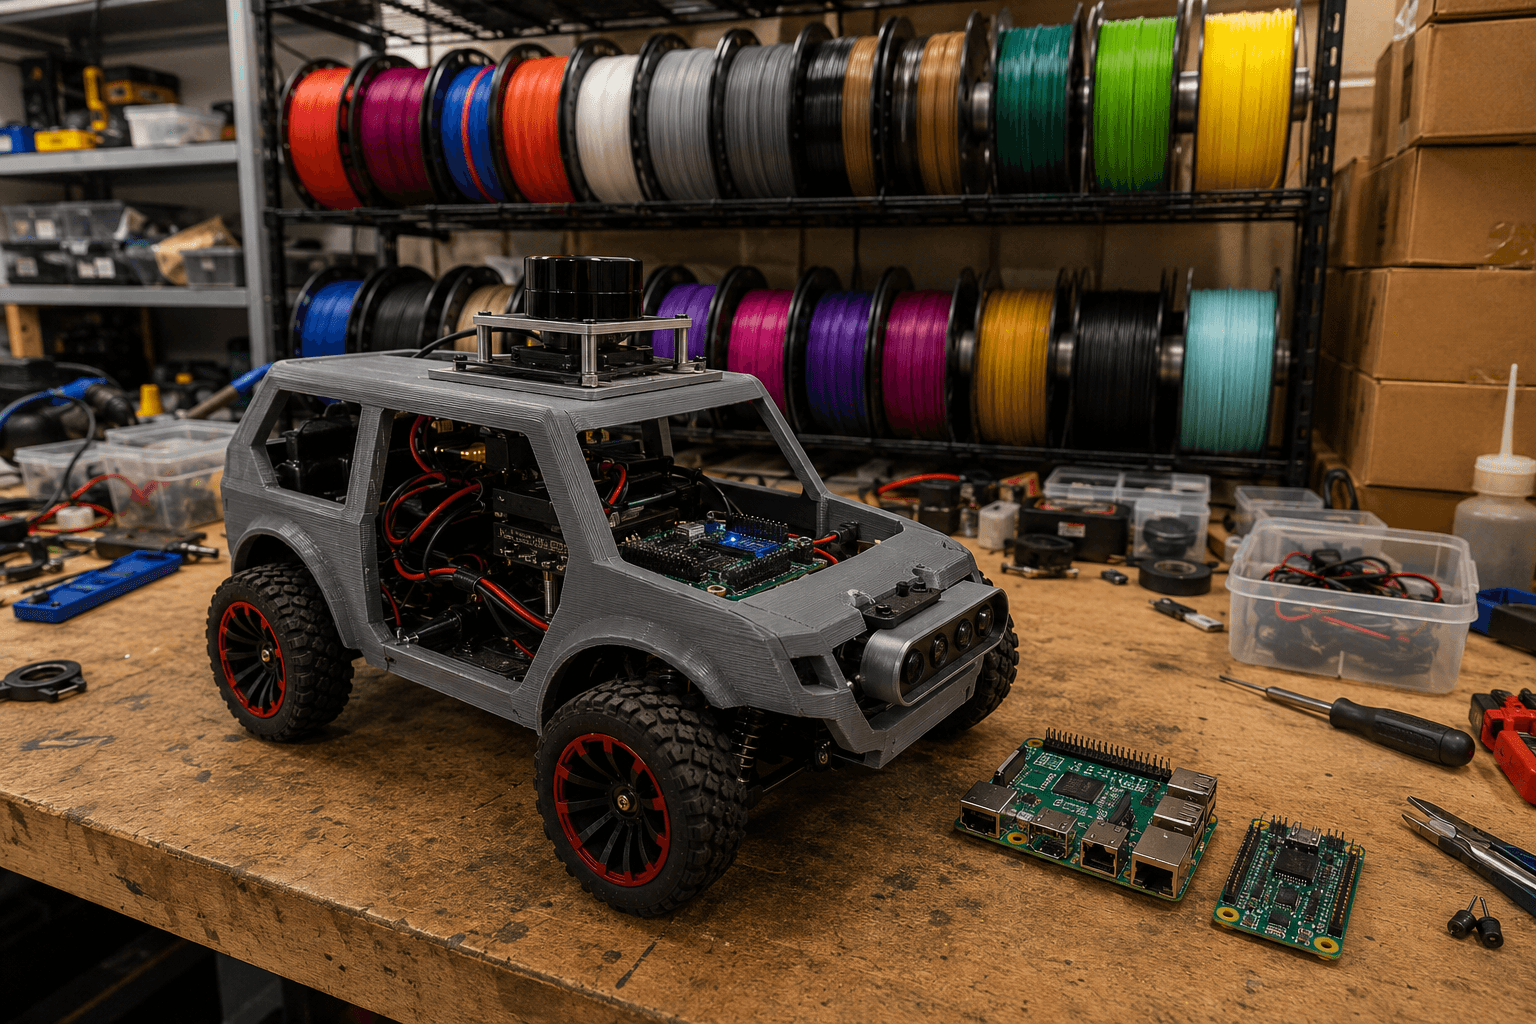
Ackermann chassis, ROS2 on a Raspberry Pi 5, and the specific joy of hearing a buzzer confirm your first boot actually worked.
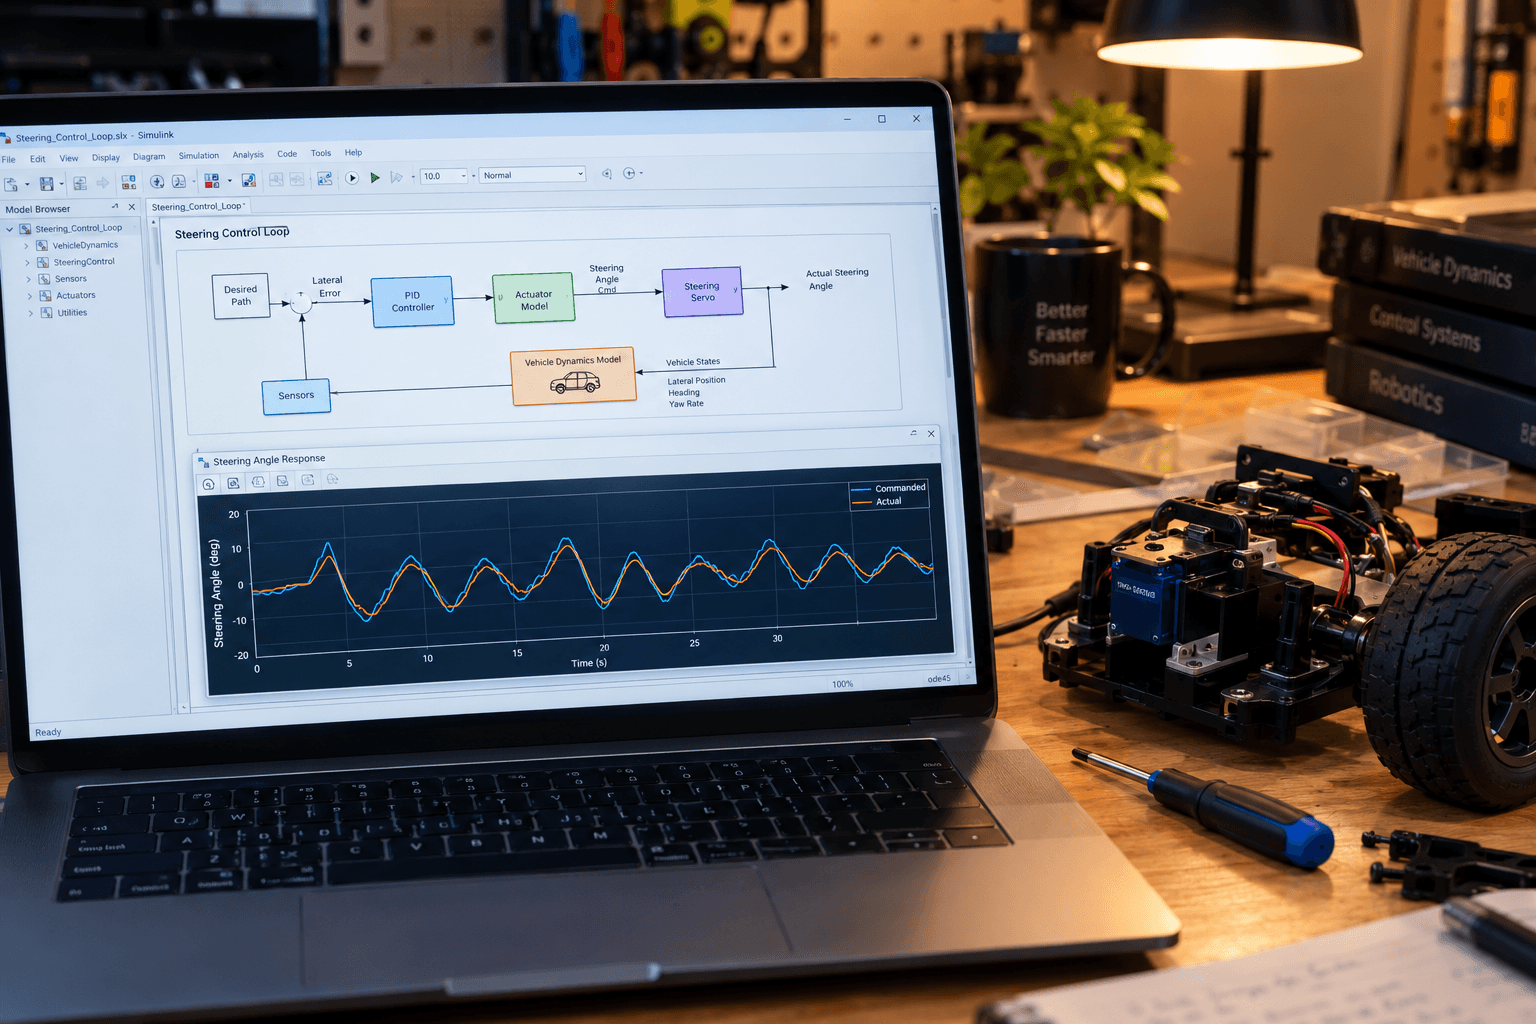
I was ready to blame the servo. The model had been telling me it was something else for two days.
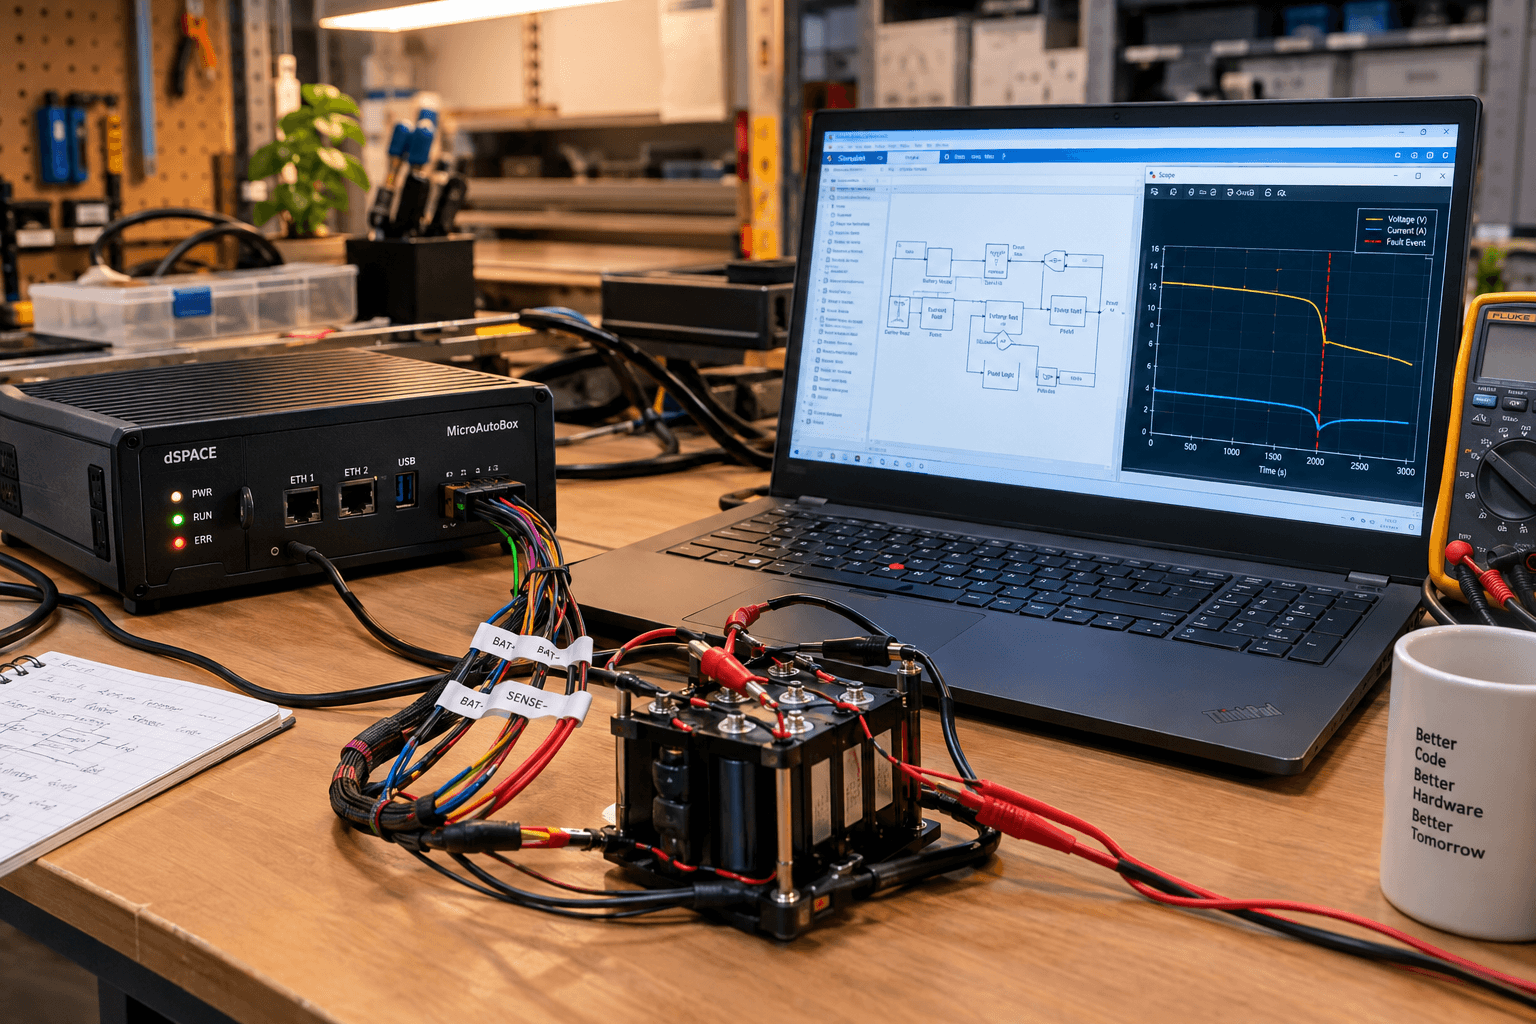
The real cell arrived three weeks late. By the time it showed up, the simulated one had already failed on us four times — for free.
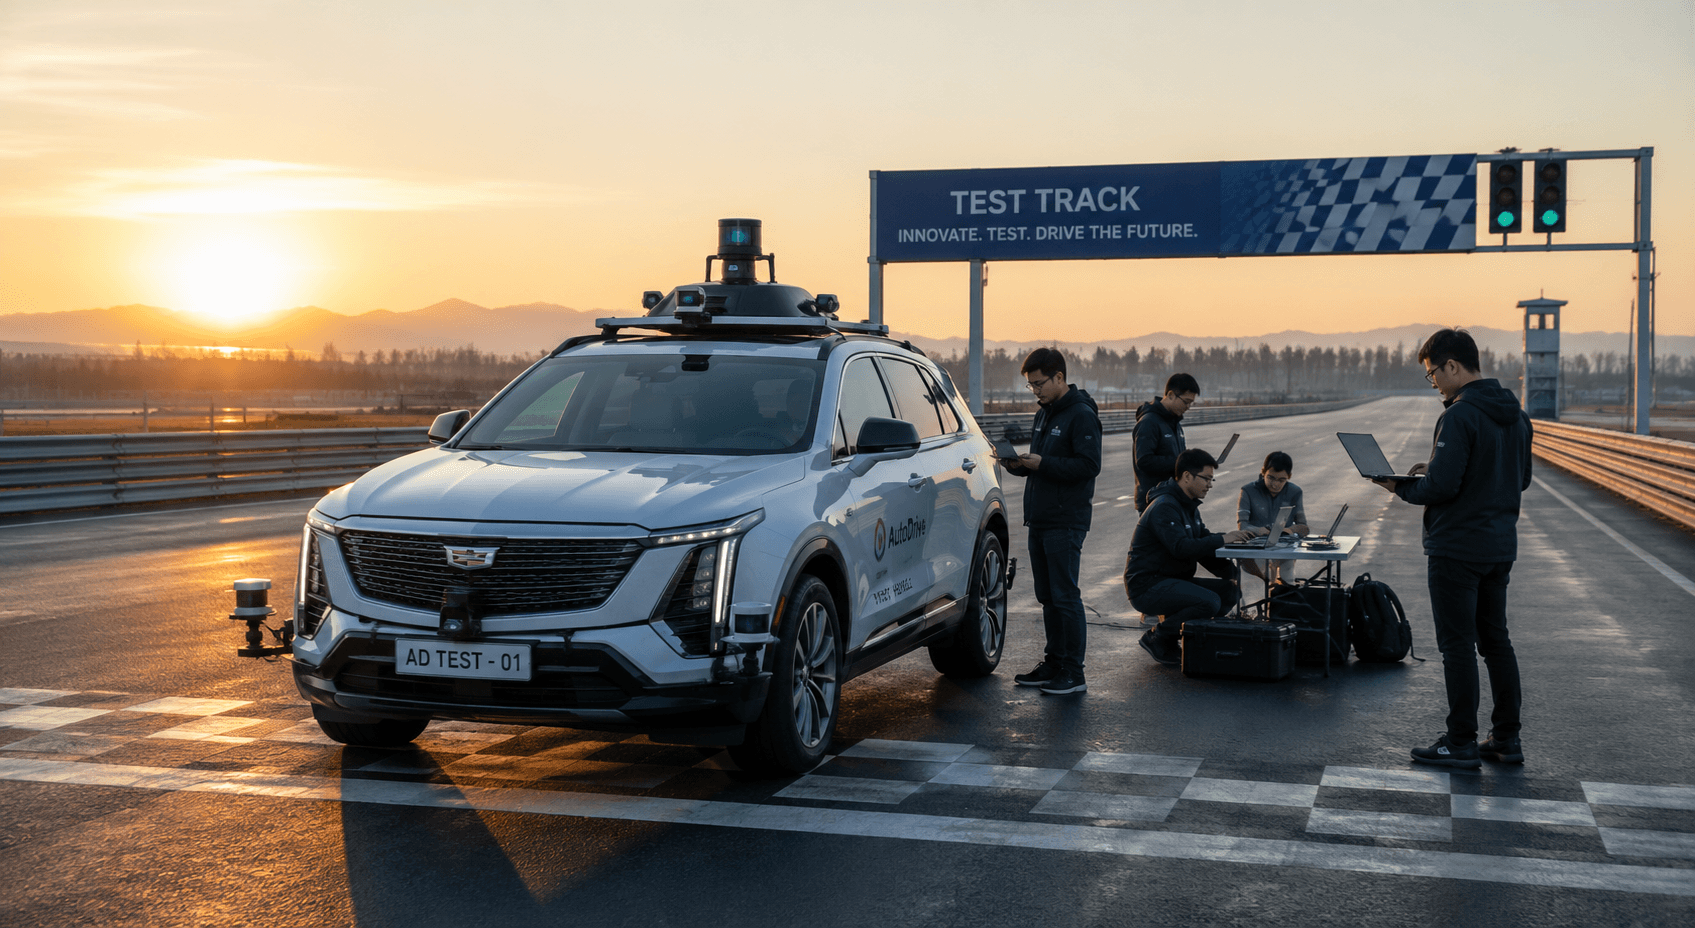
Live, present tense, as it happens. Months of bench and simulation come down to the next ninety seconds.
A candid Q&A with one of our senior engineering leads, who's sat on the other side of this table more times than he can count.
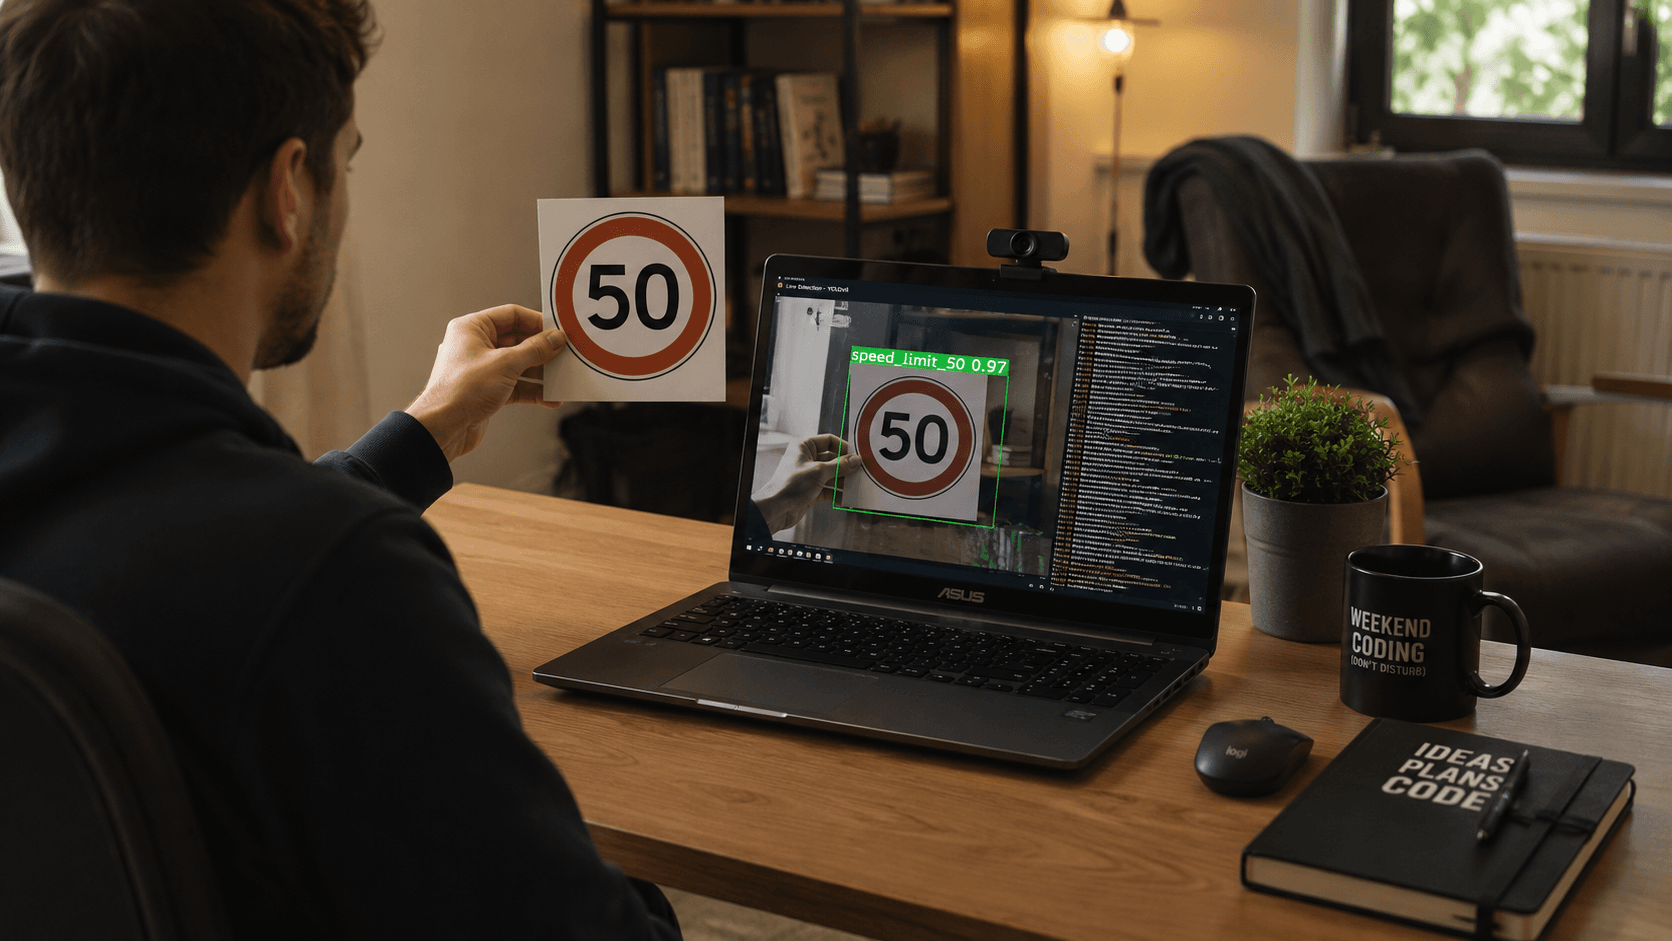
Saturday morning optimism, Saturday night driver hell, and a Sunday afternoon demo that actually worked.
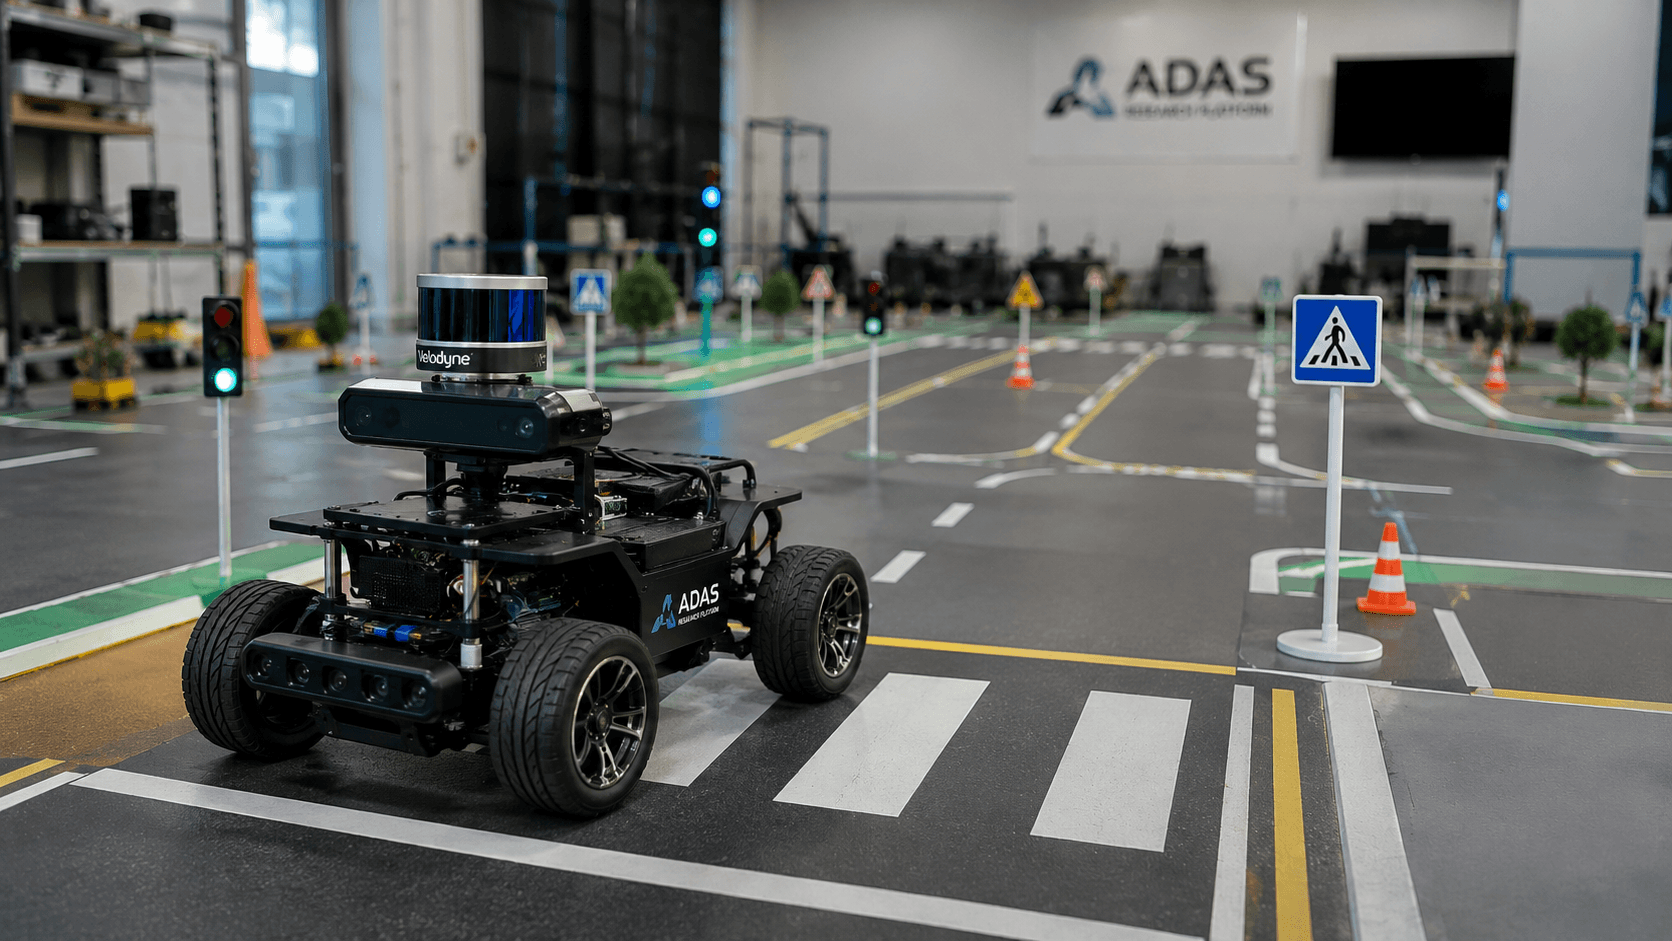
Perception, planning, vehicle control, safety logic, and HMI — at 1/10 scale, on a desk, without touching a real car.