 BlinkThorLabs
Automated Parking: Why Path Planning Is the Easy Part
The trajectory math was solved decades ago. Here's where the actual engineering effort goes instead.
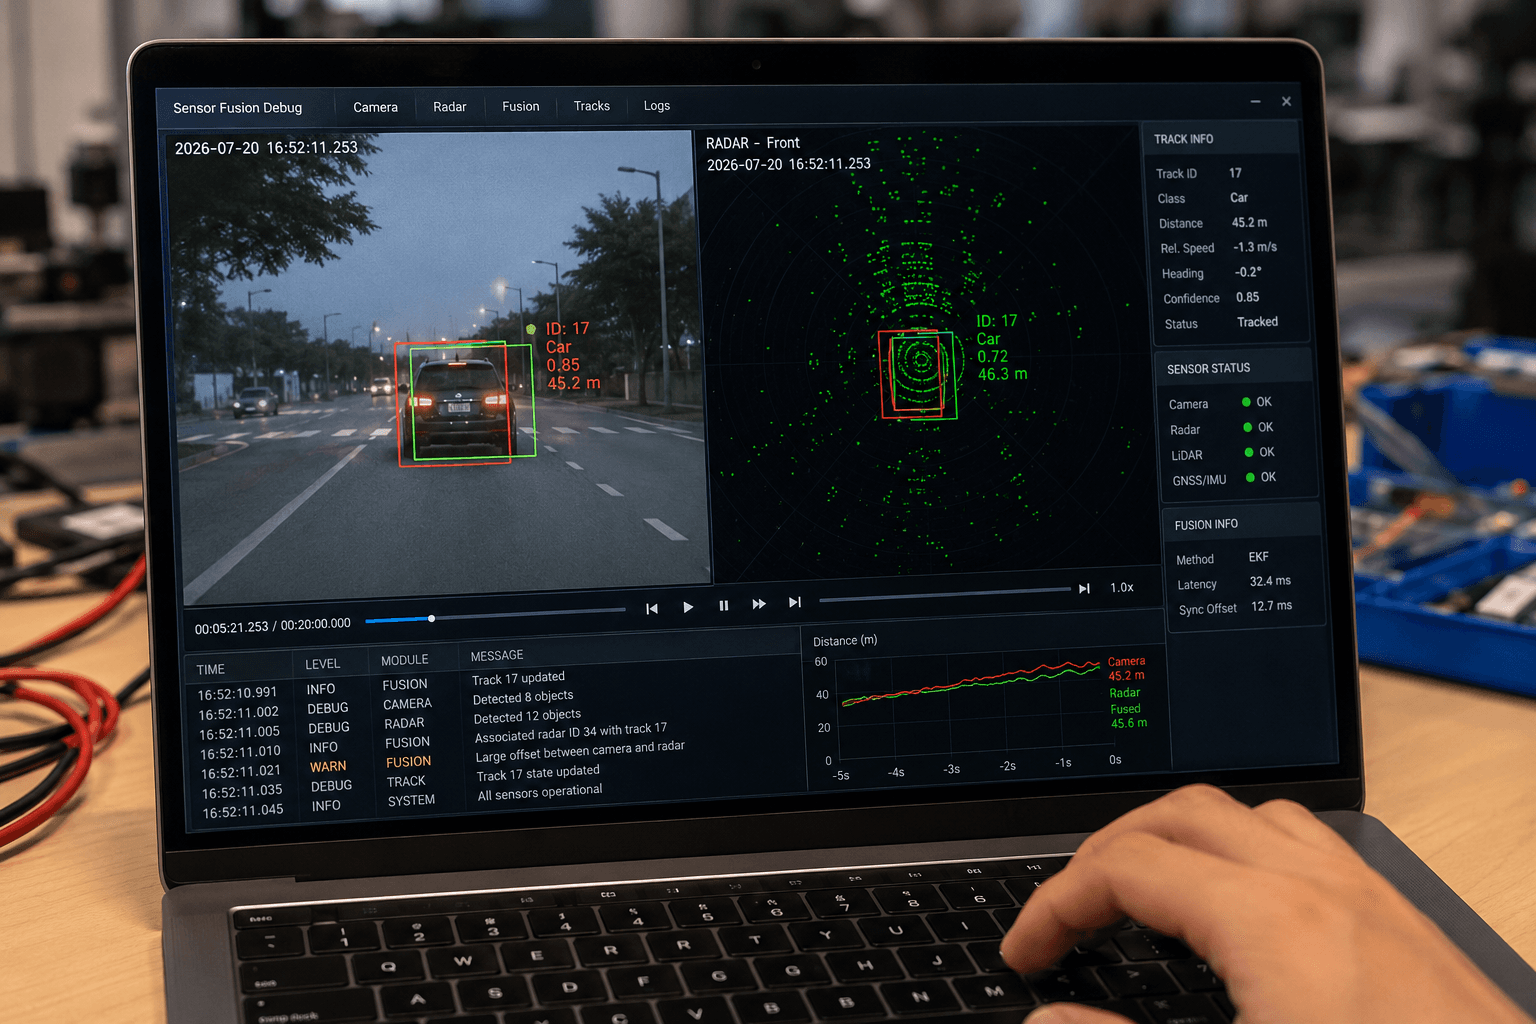
Kalman filters, camera-radar fusion, and the sensor stack behind lane-keep.
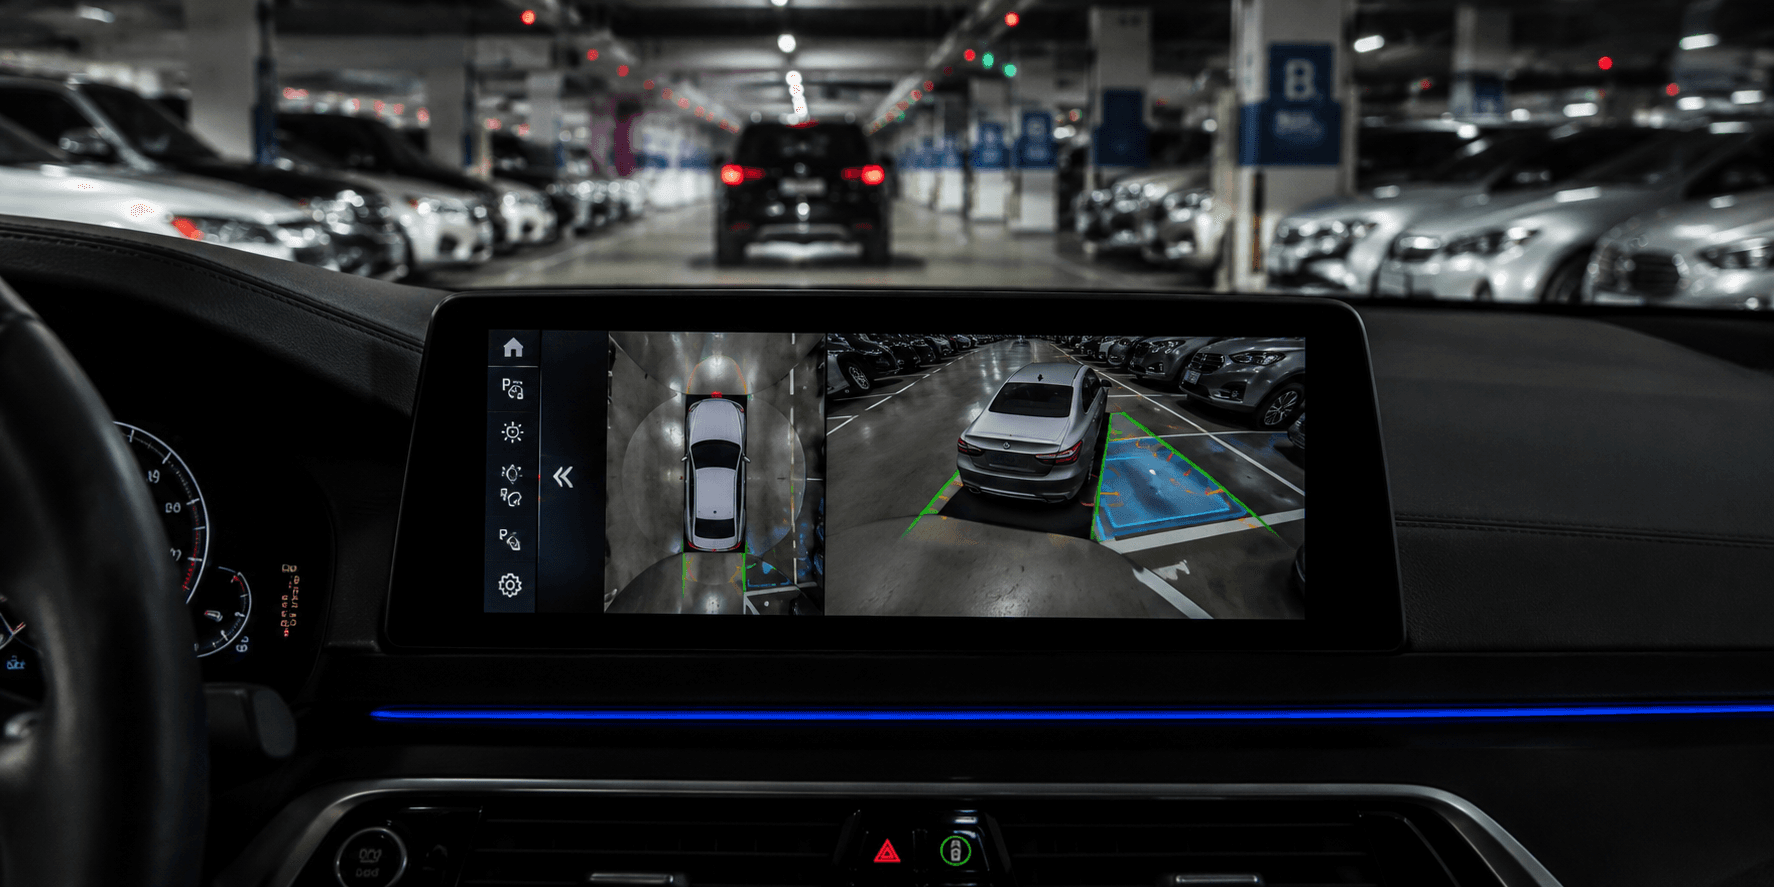
The trajectory math was solved decades ago. Here's where the actual engineering effort goes instead.
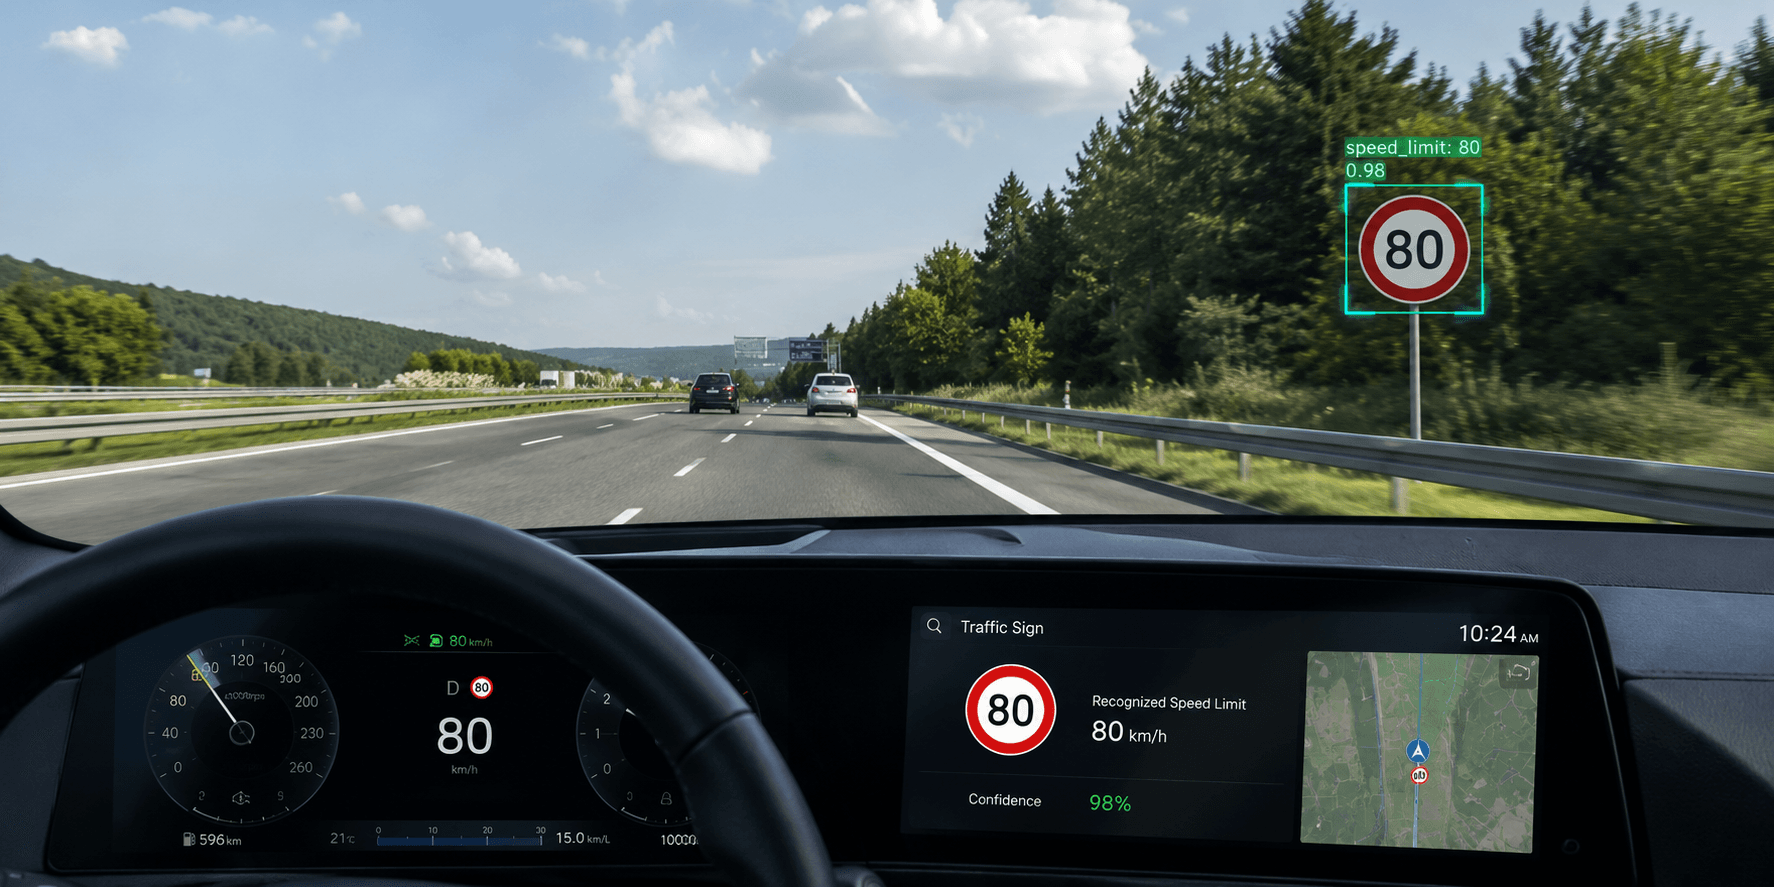
Detection finds it, classification names it, temporal fusion decides whether to trust it. Here's the full path.
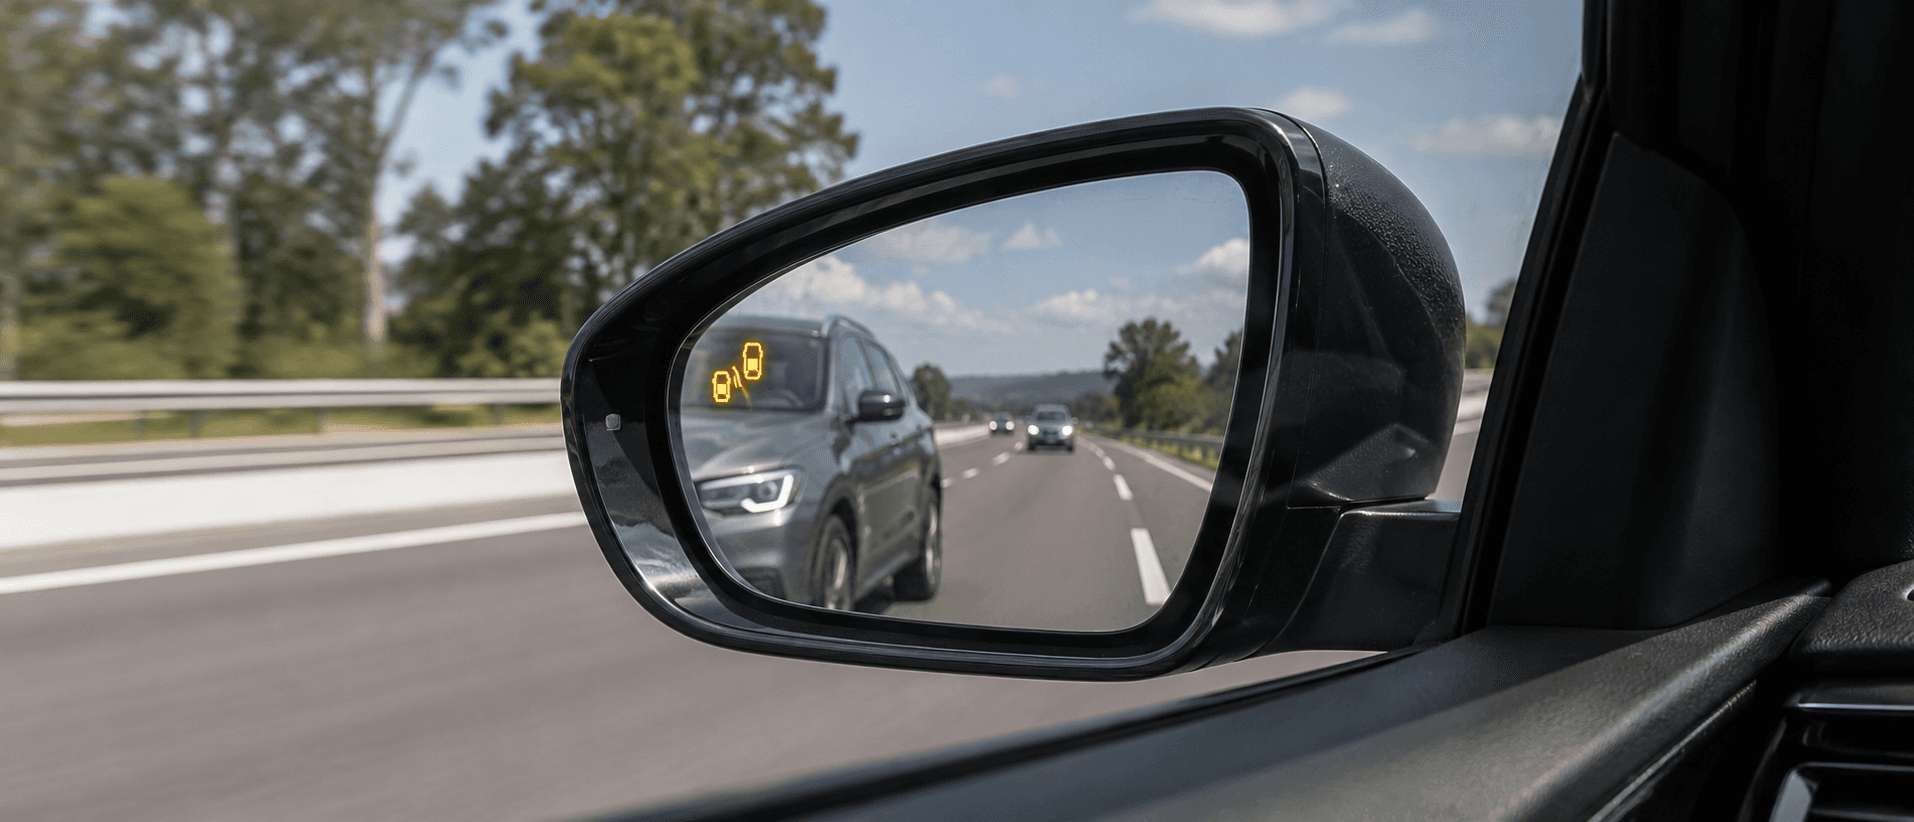
Not a driver-facing FAQ. A corrective for the misconceptions that show up in our own sales decks first.
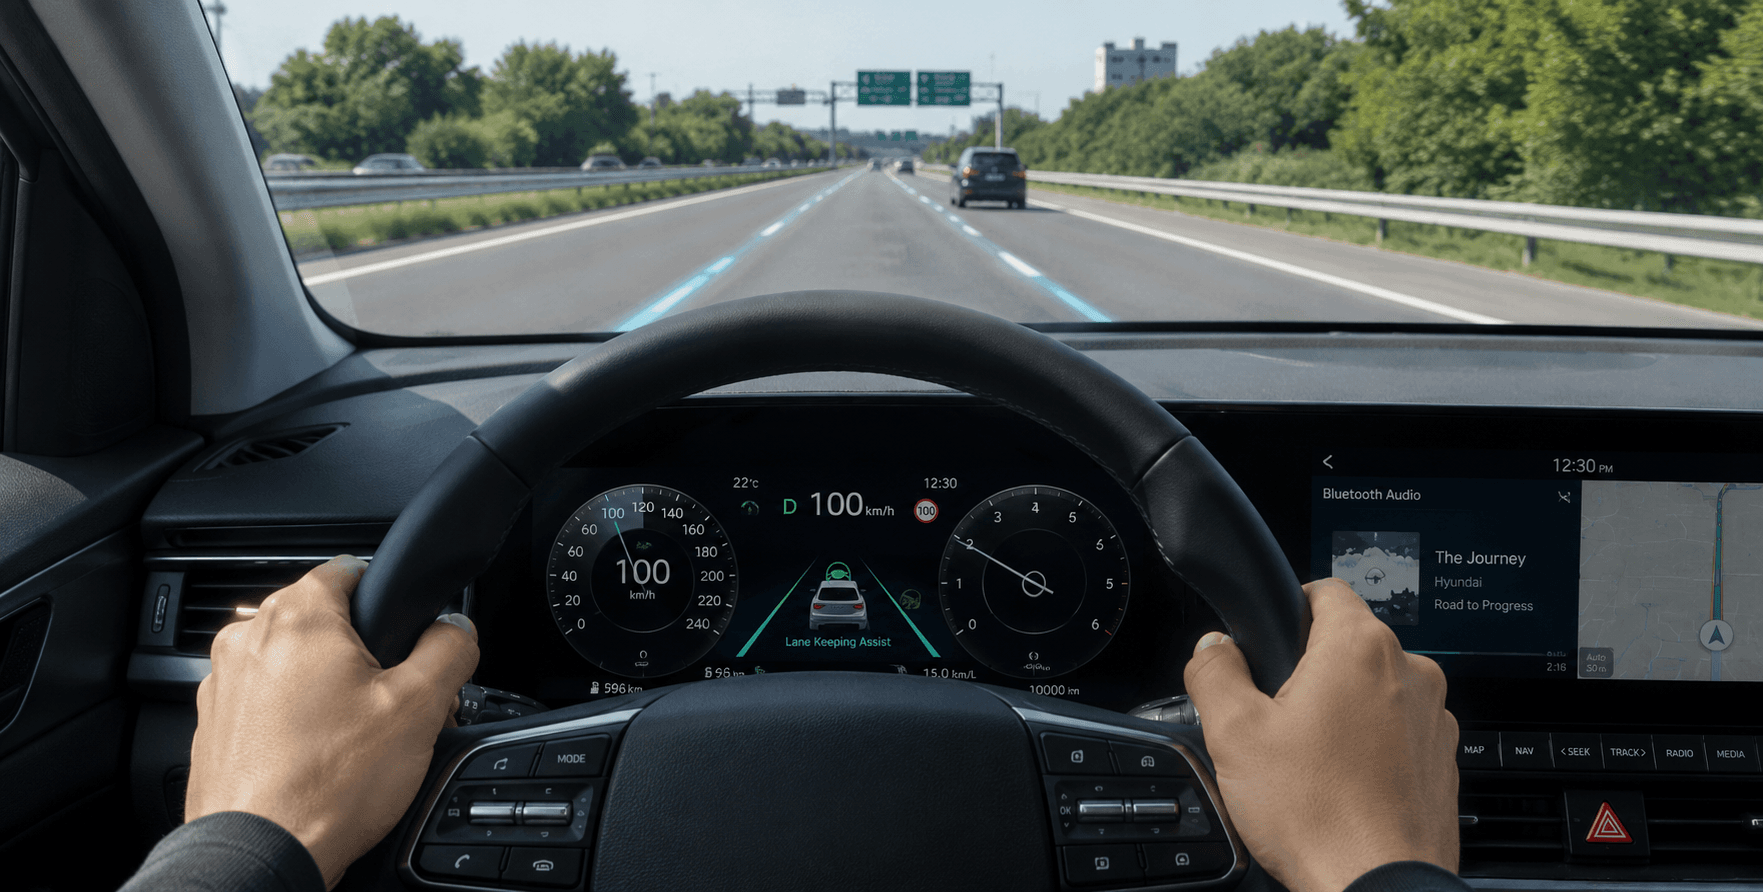
A conversation that actually happened, more or less, over a whiteboard and two cold coffees.
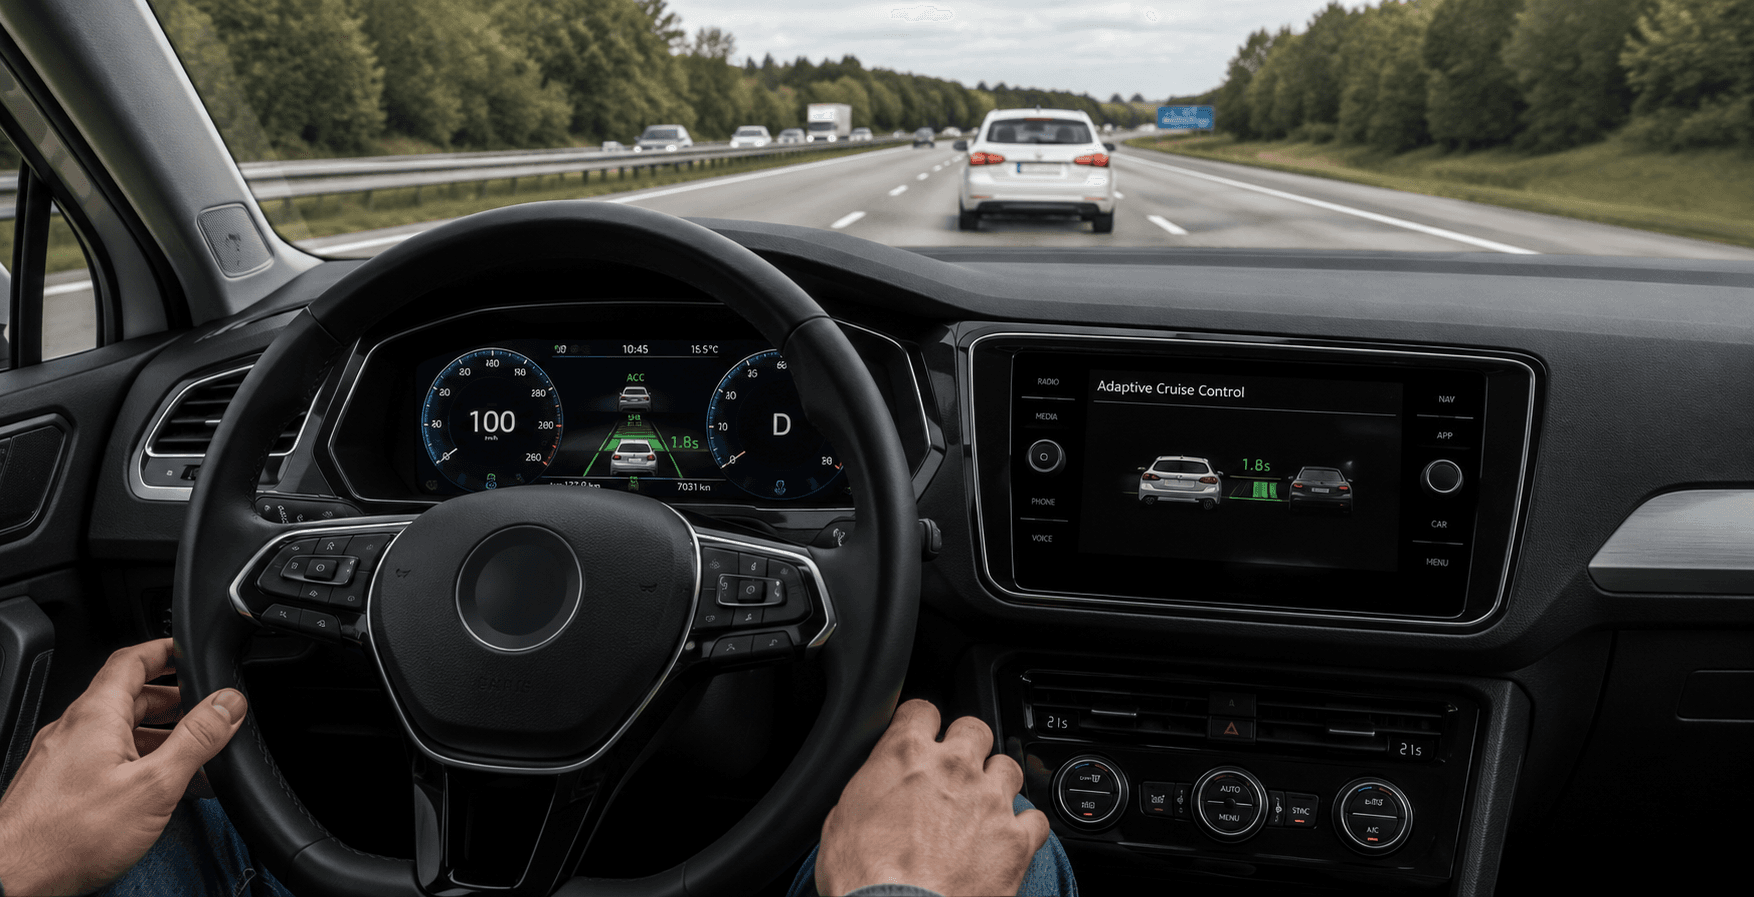
Process noise tuning matters more than your motion model — and jerk matters more than either, if you're the one sitting in the passenger seat.
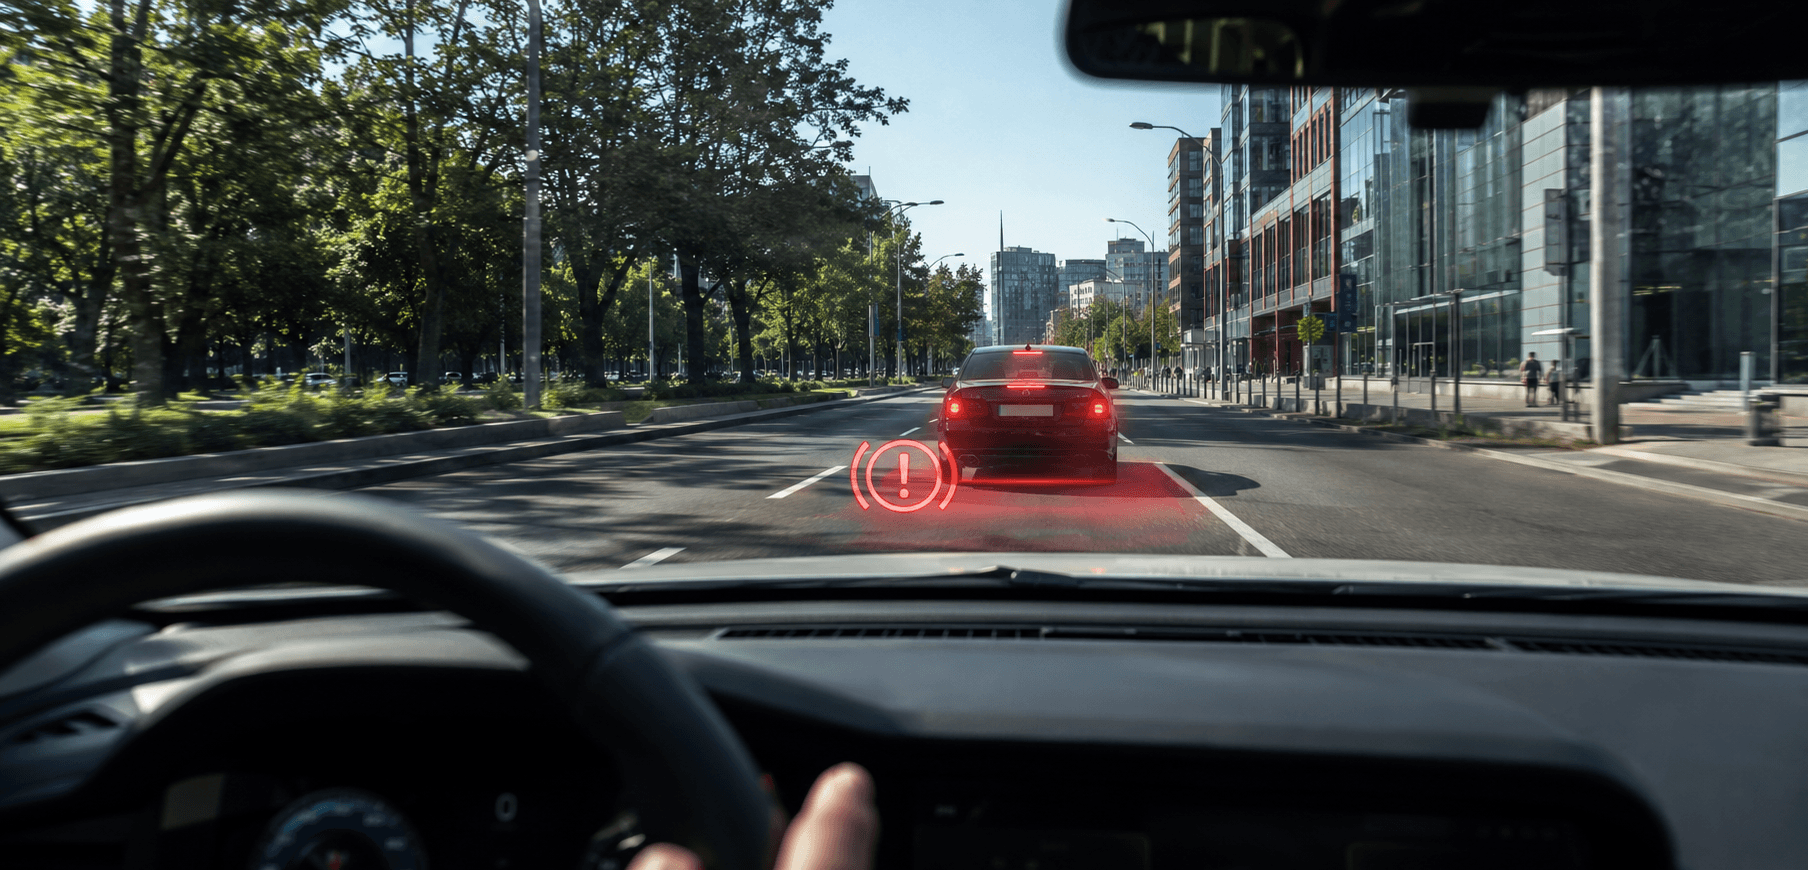
LKA/LDW, TSR, ACC, BSD — none of them carry the same weight as this one. AEB is the feature where a wrong call in either direction has real consequences.
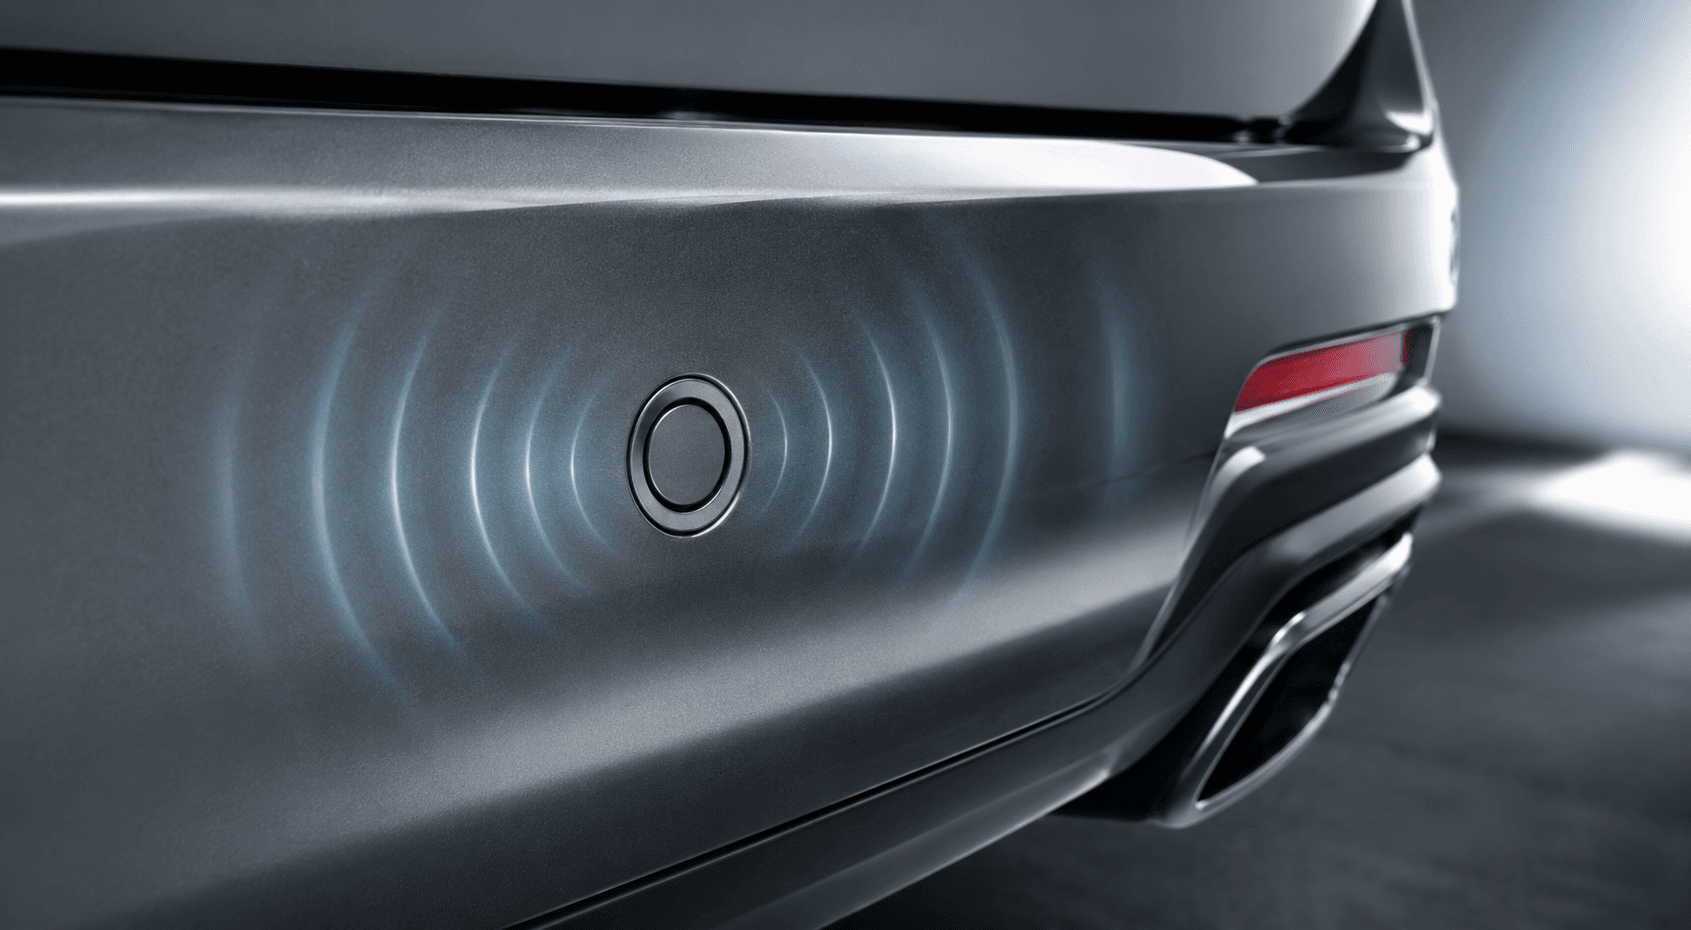
It's an echo. That's the whole idea. Here's where the idea quietly breaks.
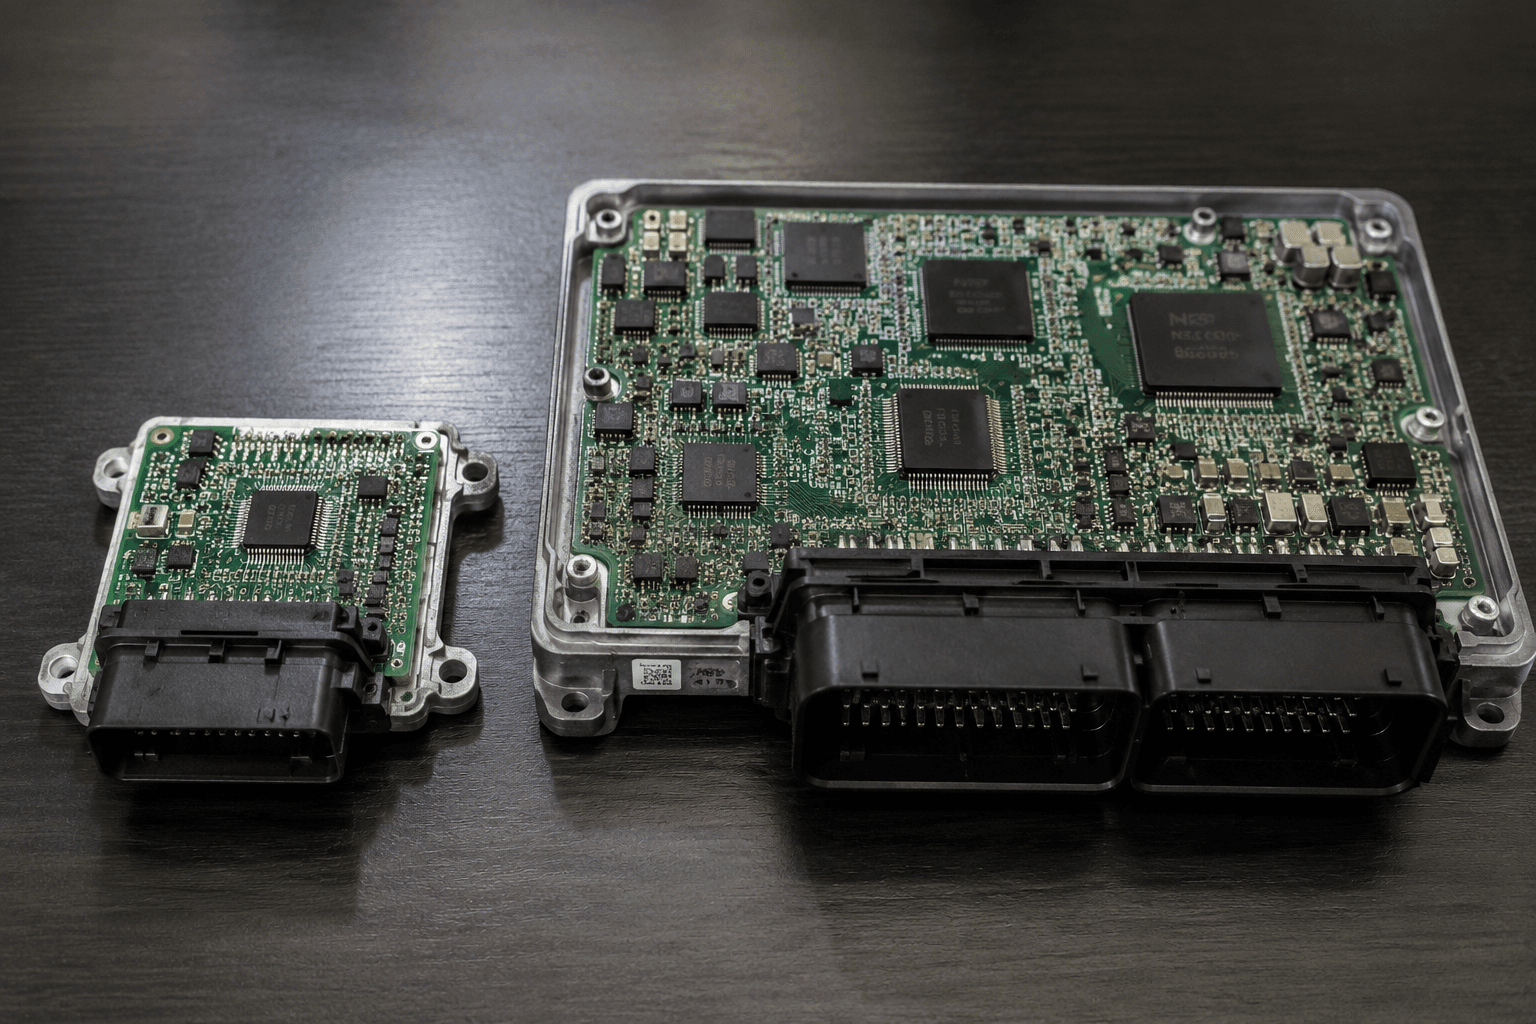
Every number on that page is true. Not all of them are true in the way you're about to assume.
A missed PTP correction cost four car-lengths of tracking error at speed.